YAM: model controlled API transfer
Physical success. The SO100 V3 checkpoint observed a live SO100 shadow scene; each newly inferred model action was converted by forward kinematics, a two anchor workspace transform, and target arm inverse kinematics before an authenticated target API command. This is not native YAM camera conditioned policy inference, retraining, or a replayed/scripted path.
Controller corrections were chosen on seed 42001; seeds 42002 and 42003 are held out follow ups using the fixed final controller: 2/2 physical successes for YAM. This small, selected seed set is not a fleet level reliability estimate. The attempt table distinguishes tuning history from follow up and never replaces a failure with a later success.
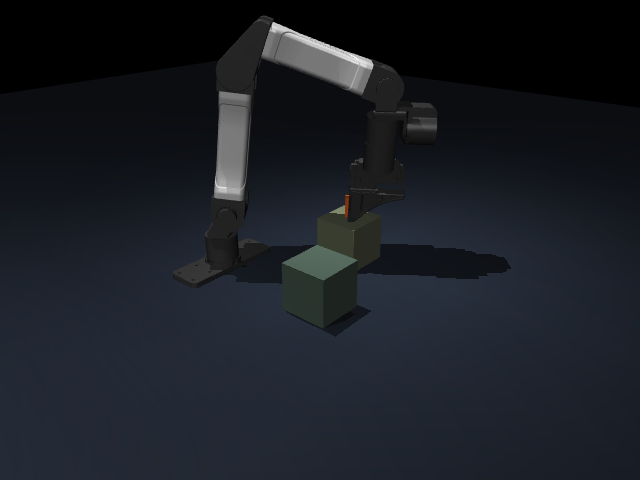
Every attempt, including failures
| Run | Physical gate | API setpoints | Model calls | Error | Evidence |
|---|---|---|---|---|---|
| yam seed42001 attempt1 | FAIL | 180 | 23 | Not recorded | Video · Trace · Outcome |
| yam seed42001 attempt2 | PASS | 401 | 51 | Not recorded | Video · Trace · Outcome |
| yam seed42002 attempt1 | PASS | 377 | 48 | Not recorded | Video · Trace · Outcome |
| yam seed42003 attempt1 | PASS | 337 | 43 | Not recorded | Video · Trace · Outcome |
Actual API call sequence
| 1 | POST /v1/sessions with robot_id=yam, scene=pick_place, manual mode, recording enabled. |
|---|---|
| 2, each tick | V3 model inference on live SO100 shadow camera/joints at each chunk boundary; GET /v1/sessions/{id}/observation?include_rgb=false on the YAM target returns measured joints and a fresh sequence. |
| 3, each tick | POST /v1/sessions/{id}/setpoint with increasing command sequence, observation sequence, lease header and target IK joint values. Acceptance is not physical completion. |
| 4, each tick | POST /v1/sessions/{id}/step advances 40 native MuJoCo steps and returns measured joints, contacts, object state and time. |
| 5 | GET /v1/sessions/{id}/cameras/overview/rgb captures real renderer frames; close session, then GET /export saves the journal. |
Counts for the selected run: 337 target observations, 337 setpoints, 350 physics steps, 0 IK failures. Example tick from the actual trace (no authentication secrets):
{
  "tick": 0,
  "api_observation_sequence": 0,
  "api_command_sequence": 0,
  "api_accepted_sequence": 0,
  "source_target": [
    0.5309028029441833,
    -1.3722734451293945,
    1.3263784646987915,
    1.6236151456832886,
    -2.1009674072265625,
    0.699999988079071
  ],
  "target_tool_goal_m": [
    0.24854906658195788,
    -0.0016476439025129817,
    0.15955210704380535
  ],
  "target_joint_target": {
    "joint1": -0.004498660669756926,
    "joint2": 1.4983425563202757,
    "joint3": 1.401610764931806,
    "joint4": -1.3009176420426312,
    "joint5": 0.0029823384967683207,
    "joint6": -0.0007929796696357223,
    "gripper": 0.03752399936097009
  },
  "target_positions": {
    "joint1": -0.0009319544215701186,
    "joint2": 1.4116157395478968,
    "joint3": 1.4593794952215824,
    "joint4": -1.2999528997217482,
    "joint5": 0.0003000976727029928,
    "joint6": -0.00015531627067669914,
    "gripper": 0.037524161295854064
  },
  "target_object": {
    "position_m": [
      0.2500009098,
      -2.715396712e-17,
      0.10006832832704898
    ],
    "quaternion_wxyz": [
      0.7071067811865477,
      0.0,
      0.0,
      0.7071067811865477
    ],
    "contacts": [
      {
        "geom": "pickup_pedestal",
        "body": "world",
        "normal_force_n": 0.061353299067769144
      },
      {
        "geom": "pickup_pedestal",
        "body": "world",
        "normal_force_n": 0.061353299067769144
      },
      {
        "geom": "pickup_pedestal",
        "body": "world",
        "normal_force_n": 0.061353299067769144
      },
      {
        "geom": "pickup_pedestal",
        "body": "world",
        "normal_force_n": 0.061353299067769144
      }
    ],
    "left_finger_force_n": 0,
    "right_finger_force_n": 0,
    "bilateral_contact": false,
    "supported": true,
    "lift_m": -5.304070083347878e-05
  }
}
Physical measurements
Acceptance requires at least 2 simulated seconds unsupported bilateral lift, one final second released and settled on the drop pedestal, less than 40 mm XY destination error, and less than 1 mm final one second drift. Selected run result: 1.04 s settled; 0.00 mm drift. All values are MuJoCo contacts and positions, not video interpretation.
Measured object path
Object lift (mm)
Bilateral contact
Outcome and mapping · Full per tick model/API/physics trace · API episode journal · HTTP server log · Model load log
SO101: model controlled API transfer
Physical success. The SO100 V3 checkpoint observed a live SO100 shadow scene; each newly inferred model action was converted by forward kinematics, a two anchor workspace transform, and target arm inverse kinematics before an authenticated target API command. This is not native SO101 camera conditioned policy inference, retraining, or a replayed/scripted path.
Controller corrections were chosen on seed 42001; seeds 42002 and 42003 are held out follow ups using the fixed final controller: 2/2 physical successes for SO101. This small, selected seed set is not a fleet level reliability estimate. The attempt table distinguishes tuning history from follow up and never replaces a failure with a later success.
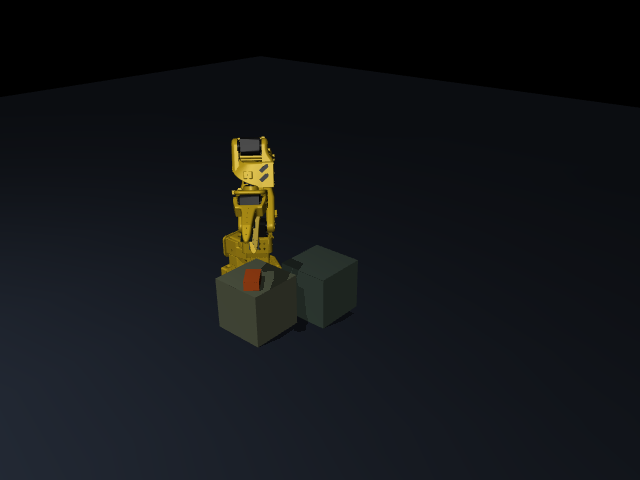
Every attempt, including failures
| Run | Physical gate | API setpoints | Model calls | Error | Evidence |
|---|---|---|---|---|---|
| so101 seed42001 attempt1 | FAIL | 180 | 23 | Not recorded | Video · Trace · Outcome |
| so101 seed42001 attempt2 | FAIL | 198 | 25 | HTTPStatusError: Client error '422 Unprocessable Entity' for url 'http://127.0.0.1:8000/v1/sessions/s_0254619f387b45df96f737a8017eaf88/setpoint' For more information check: https://developer.mozilla.org/en US/docs/Web/HTTP/Status/422 | Video ·. · Outcome |
| so101 seed42001 attempt3 | FAIL | 198 | 25 | HTTPStatusError: Client error '422 Unprocessable Entity' for url 'http://127.0.0.1:8000/v1/sessions/s_6b7c4f019c2a416181d43e929bd6a5bb/setpoint' For more information check: https://developer.mozilla.org/en US/docs/Web/HTTP/Status/422 | Video · Trace · Outcome |
| so101 seed42001 attempt4 | FAIL | 401 | 51 | Not recorded | Video · Trace · Outcome |
| so101 seed42001 attempt5 | FAIL | 401 | 51 | Not recorded | Video · Trace · Outcome |
| so101 seed42001 attempt6 | PASS | 401 | 51 | Not recorded | Video · Trace · Outcome |
| so101 seed42002 attempt1 | PASS | 377 | 48 | Not recorded | Video · Trace · Outcome |
| so101 seed42003 attempt1 | PASS | 338 | 43 | Not recorded | Video · Trace · Outcome |
Actual API call sequence
| 1 | POST /v1/sessions with robot_id=so101, scene=pick_place, manual mode, recording enabled. |
|---|---|
| 2, each tick | V3 model inference on live SO100 shadow camera/joints at each chunk boundary; GET /v1/sessions/{id}/observation?include_rgb=false on the SO101 target returns measured joints and a fresh sequence. |
| 3, each tick | POST /v1/sessions/{id}/setpoint with increasing command sequence, observation sequence, lease header and target IK joint values. Acceptance is not physical completion. |
| 4, each tick | POST /v1/sessions/{id}/step advances 40 native MuJoCo steps and returns measured joints, contacts, object state and time. |
| 5 | GET /v1/sessions/{id}/cameras/overview/rgb captures real renderer frames; close session, then GET /export saves the journal. |
Counts for the selected run: 338 target observations, 338 setpoints, 351 physics steps, 0 IK failures. Example tick from the actual trace (no authentication secrets):
{
  "tick": 0,
  "api_observation_sequence": 0,
  "api_command_sequence": 0,
  "api_accepted_sequence": 0,
  "source_target": [
    0.5309028029441833,
    -1.3722734451293945,
    1.3263784646987915,
    1.6236151456832886,
    -2.1009674072265625,
    0.699999988079071
  ],
  "target_tool_goal_m": [
    0.18588802955942904,
    6.789120500600258e-05,
    0.194555860062779
  ],
  "target_joint_target": {
    "shoulder_pan": -0.0016564132629382545,
    "shoulder_lift": -0.9555073943692493,
    "elbow_flex": 0.1453621677642259,
    "wrist_flex": 1.6333634554968275,
    "wrist_roll": 8.610624509433877e-19,
    "gripper": 0.9999999799978735
  },
  "target_positions": {
    "shoulder_pan": -0.0016388433693159225,
    "shoulder_lift": -0.9543858932695792,
    "elbow_flex": 0.14676718339919942,
    "wrist_flex": 1.633470392622948,
    "wrist_roll": -6.951533982584702e-08,
    "gripper": 0.9999963786772659
  },
  "target_object": {
    "position_m": [
      0.18460905,
      5.799917456000146e-06,
      0.10007208234258336
    ],
    "quaternion_wxyz": [
      0.9997186370071134,
      6.2436799921968536e-18,
      1.8016201939805703e-18,
      -0.023720177500168776
    ],
    "contacts": [
      {
        "geom": "pickup_pedestal",
        "body": "world",
        "normal_force_n": 0.06135329905581372
      },
      {
        "geom": "pickup_pedestal",
        "body": "world",
        "normal_force_n": 0.06135329905581372
      },
      {
        "geom": "pickup_pedestal",
        "body": "world",
        "normal_force_n": 0.061353299055813715
      },
      {
        "geom": "pickup_pedestal",
        "body": "world",
        "normal_force_n": 0.061353299055813736
      }
    ],
    "left_finger_force_n": 0,
    "right_finger_force_n": 0,
    "bilateral_contact": false,
    "supported": true,
    "lift_m": -5.3040697683498506e-05
  }
}
Physical measurements
Acceptance requires at least 2 simulated seconds unsupported bilateral lift, one final second released and settled on the drop pedestal, less than 40 mm XY destination error, and less than 1 mm final one second drift. Selected run result: 1.04 s settled; 0.00 mm drift. All values are MuJoCo contacts and positions, not video interpretation.
Measured object path
Object lift (mm)
Bilateral contact
Outcome and mapping · Full per tick model/API/physics trace · API episode journal · HTTP server log · Model load log
Separate scripted API baselines. not policy evidence
These are precomputed API commands, retained only as physical engine and API baselines. Their success is excluded from all model controlled claims.
YAM: pick, carry, place, release
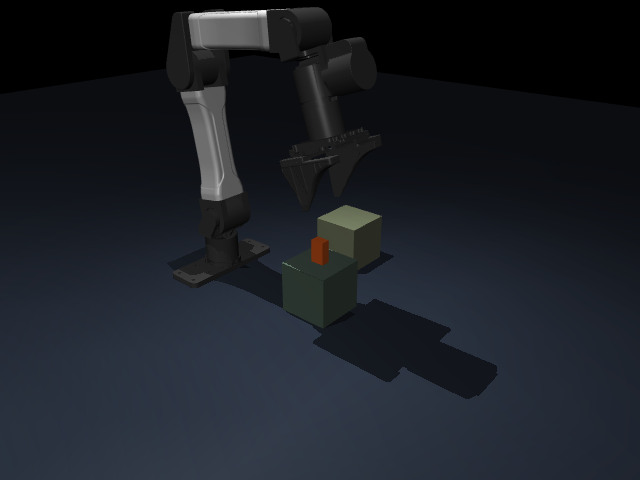
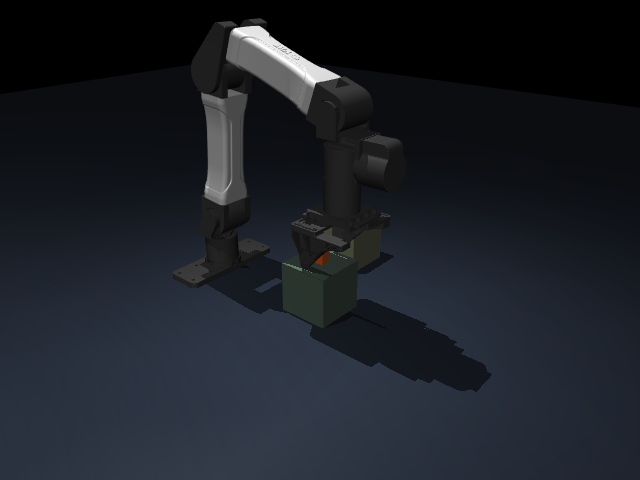
Observed motion phases: Ready → Approach → Grasp → Lift → Transfer → Lower → Release → Retreat. The object moved through genuine frictional MuJoCo contacts; the evaluator did not weld it to the gripper or overwrite its pose.
Visual timeline
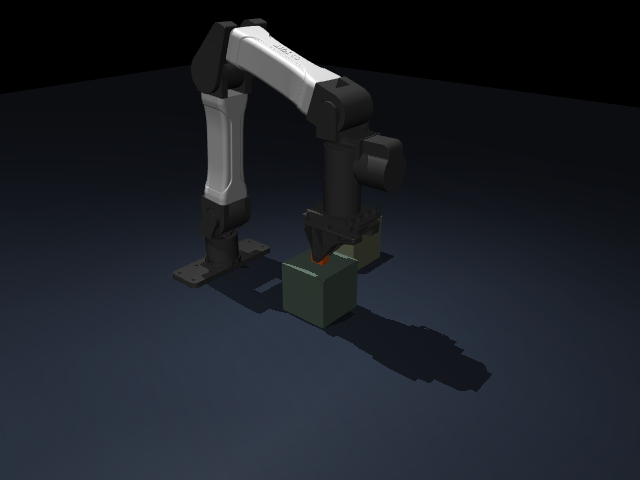
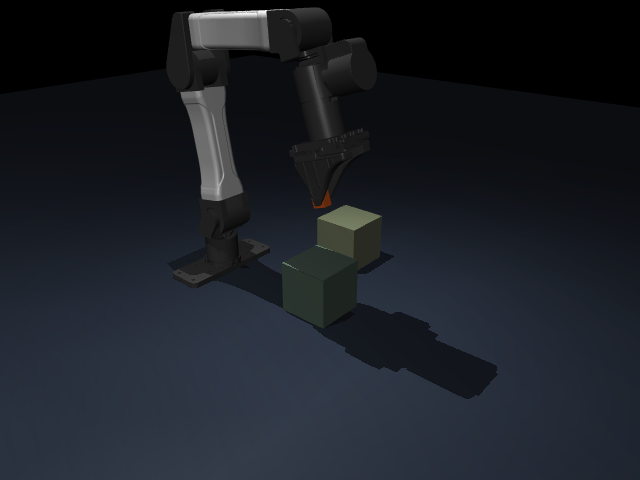
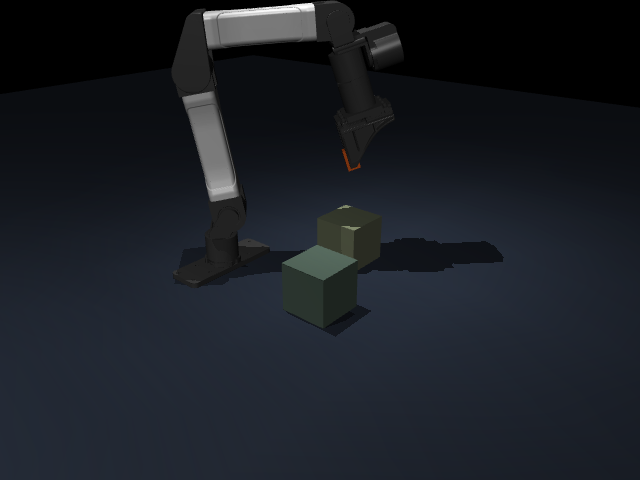
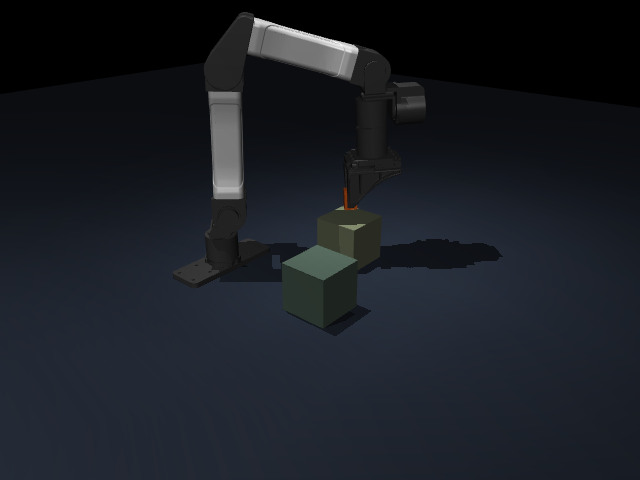
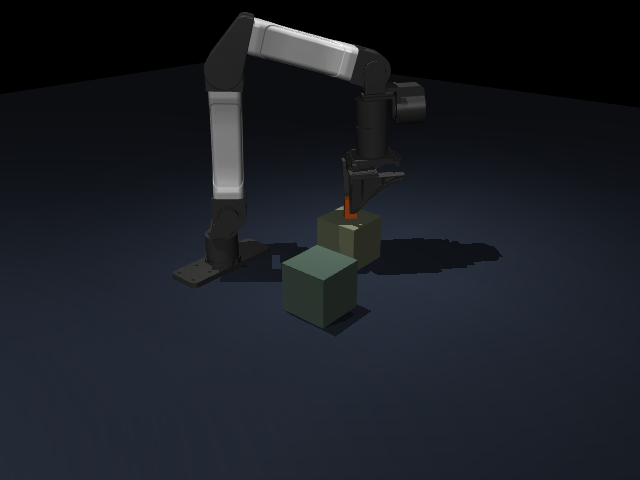
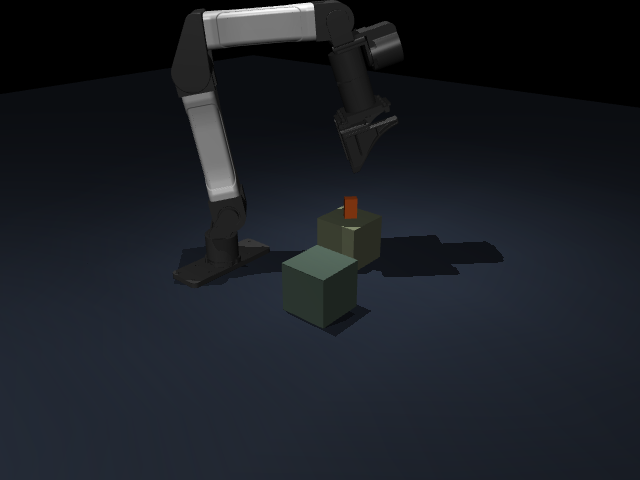
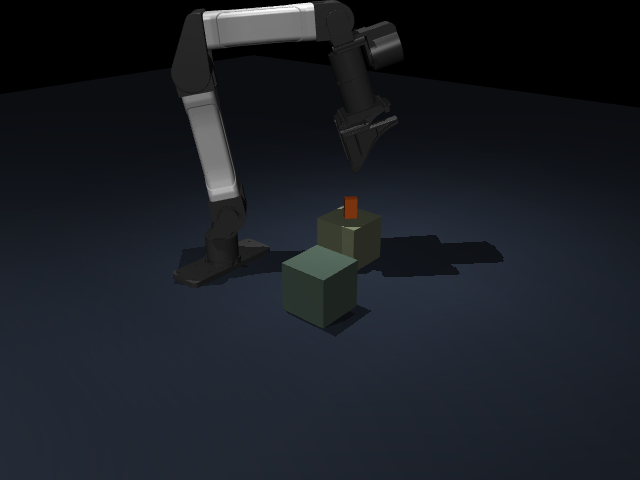
Physical task measurements
| Unsupported bilateral lift | 10.28 simulated seconds |
|---|---|
| Final placement error | 0.001023 m |
| Final one second object drift | 0.000000 m |
| Settled release | 25 frames |
| Object mass | 0.025 kg |
| Object size | [0.016, 0.024, 0.04] m |
| Pickup position | [0.2500009098366757, -2.7153967119061406e-17, 0.10012136902788246] m |
| Destination position | [0.17417713860911788, 0.17933949766865334, 0.10012136902788246] m |
| Contact model | MuJoCo frictional contacts; no weld or object pose writes |
Measured object XY path
Object lift, millimeters
Bilateral jaw contact, 0 or 1
Result JSON · 900 frame state trace · API episode journal · Command runs · API server log
SO101: pick, carry, place, release
Observed motion phases: Ready → Approach → Grasp → Lift → Transfer → Lower → Release → Retreat. The object moved through genuine frictional MuJoCo contacts; the evaluator did not weld it to the gripper or overwrite its pose.
Visual timeline
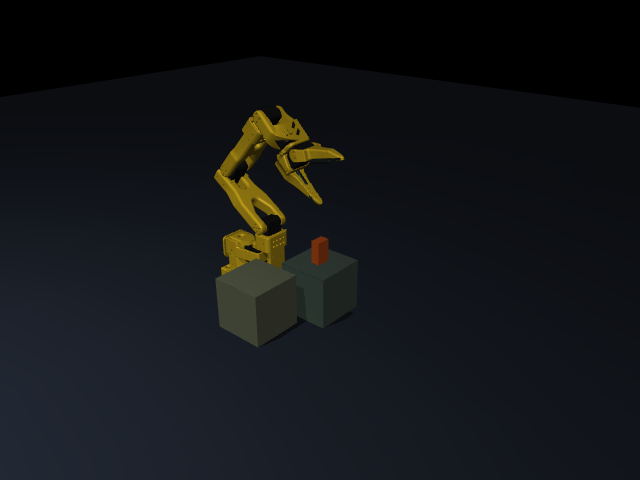
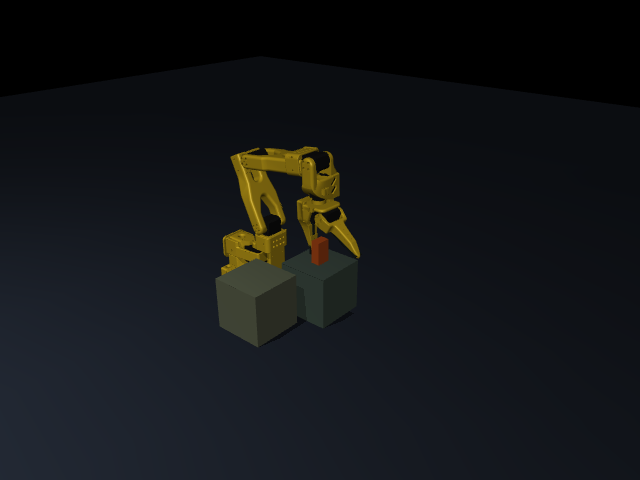
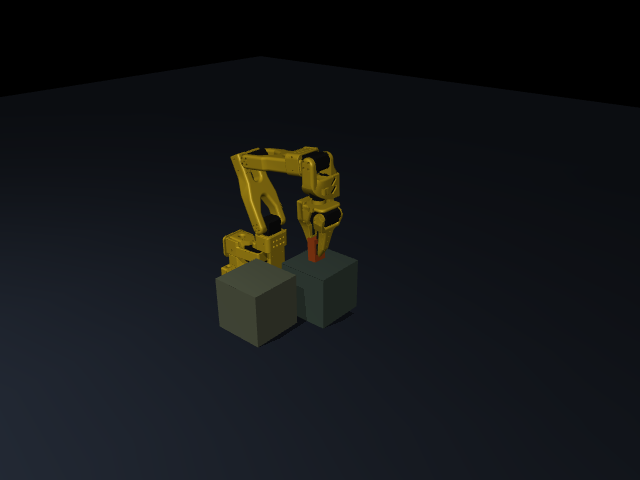
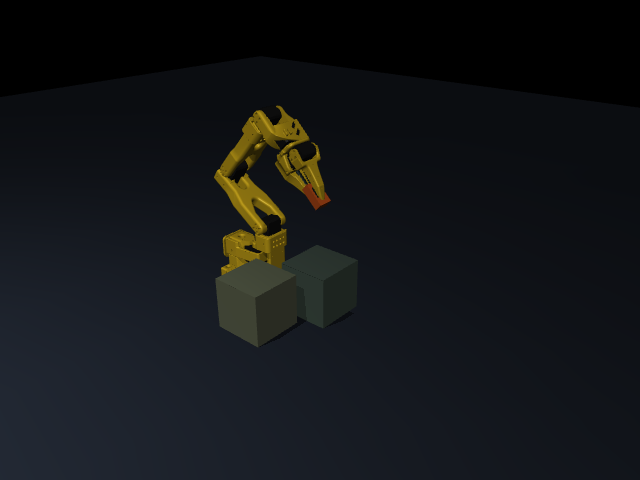
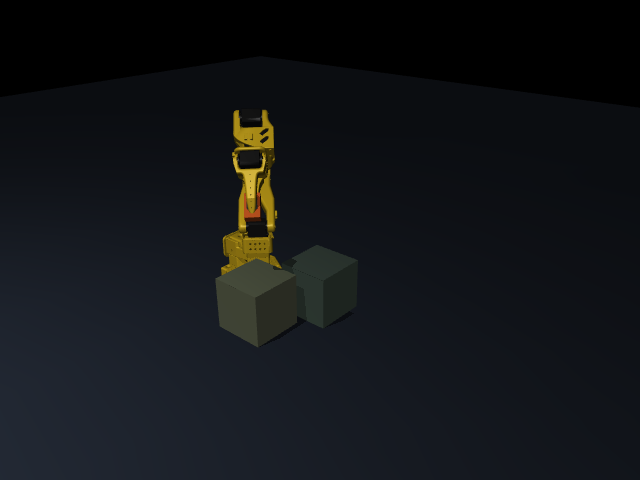
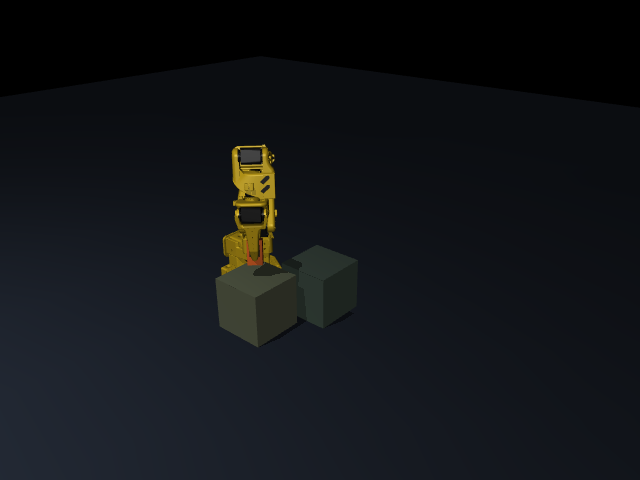
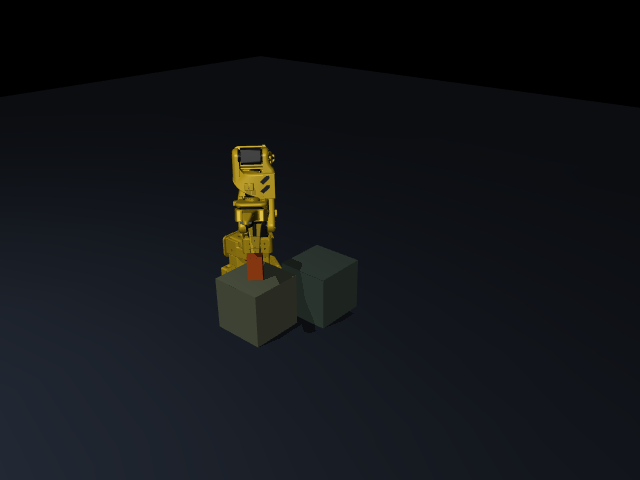
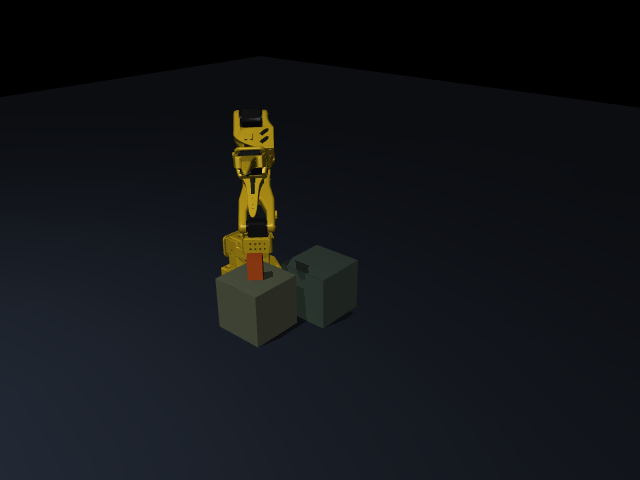
Physical task measurements
| Unsupported bilateral lift | 10.20 simulated seconds |
|---|---|
| Final placement error | 0.003233 m |
| Final one second object drift | 0.000000 m |
| Settled release | 25 frames |
| Object mass | 0.025 kg |
| Object size | [0.016, 0.024, 0.04] m |
| Pickup position | [0.18460904999305738, 5.799917456049495e-06, 0.10012512304026686] m |
| Destination position | [0.14039968358821892, -0.10456627691997465, 0.10012512304026686] m |
| Contact model | MuJoCo frictional contacts; no weld or object pose writes |
Measured object XY path
Object lift, millimeters
Bilateral jaw contact, 0 or 1
Result JSON · 900 frame state trace · API episode journal · Command runs · API server log
Evaluation and provenance
Each arm used its calibrated pick_place scene with a 25 g object. API command completion was necessary but not sufficient: the gate checked physical lift, release near the target, and settled end state. MuJoCo physics ran on CPU; NVIDIA A40 EGL rendered the videos.
Scripted baseline data · Offline 52 pose FK/IK feasibility probe · NVIDIA renderer · Downloaded evidence checksums
Publication record
This site contains the report pages and their linked evidence. Session lease values were removed from publication copies of API journals. The original evaluation files remain unchanged. Source and published file hashes record the exported files and redactions.